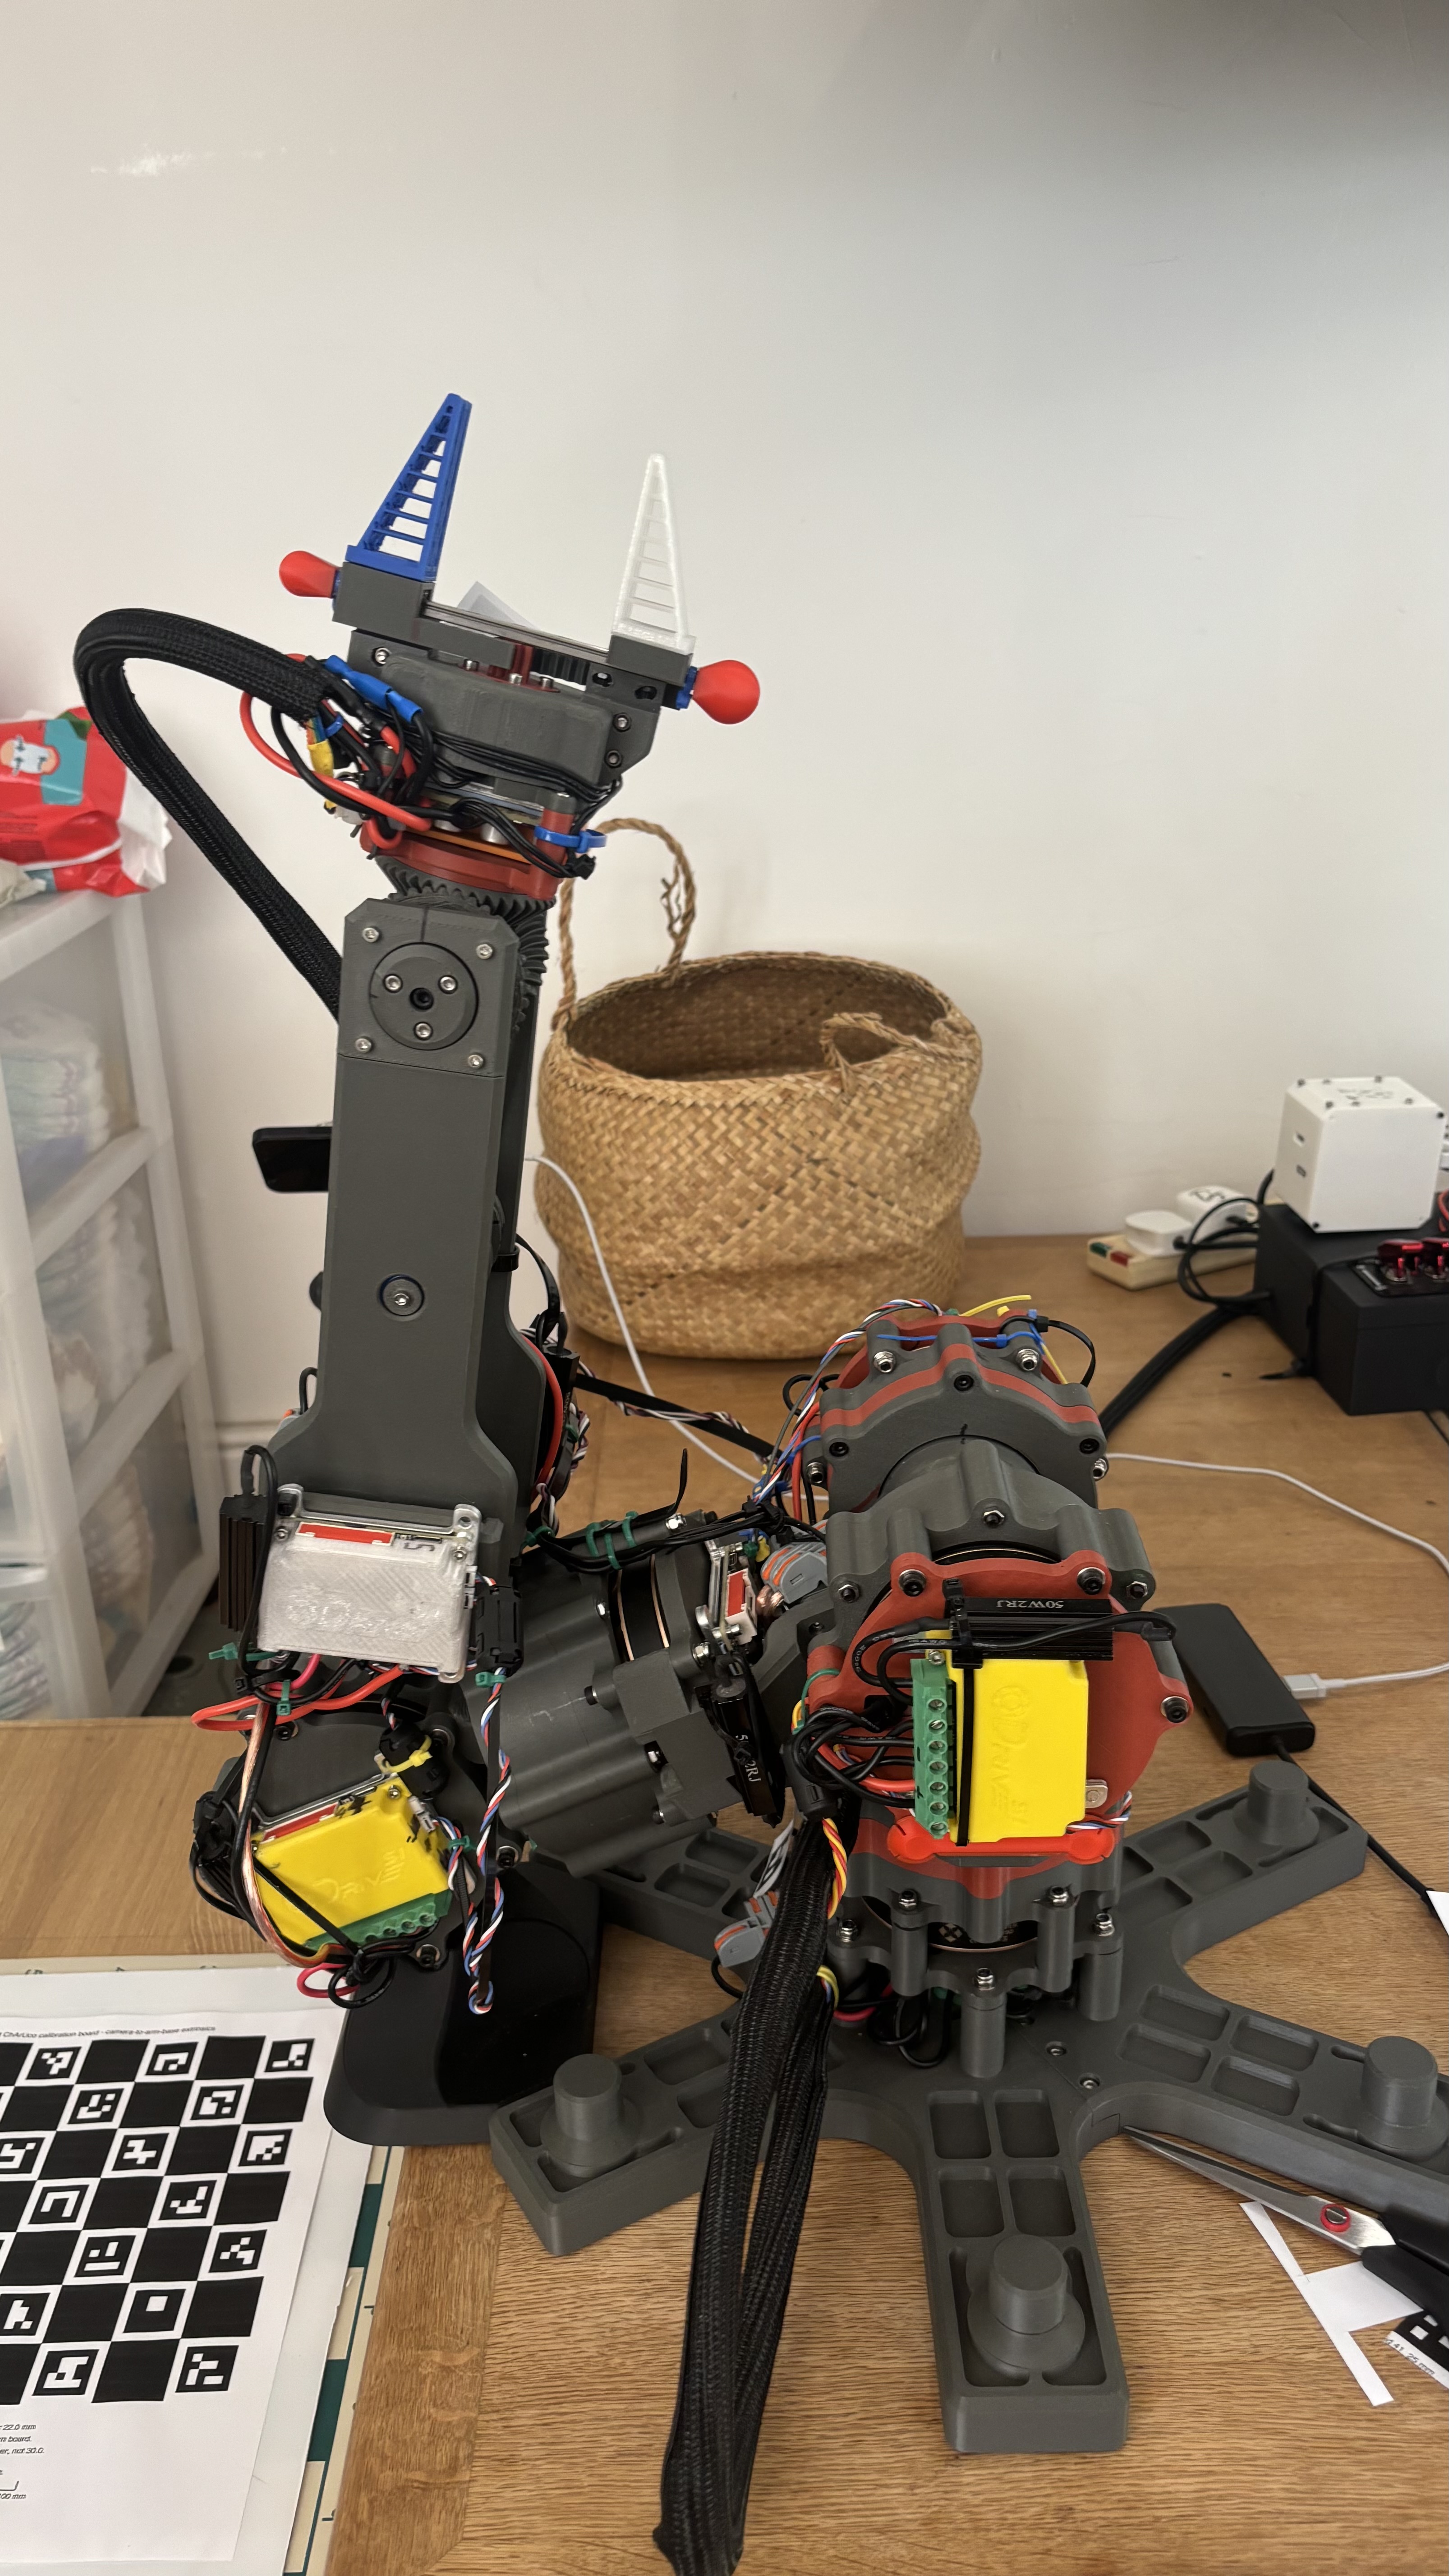
So I 3D printed and built this 6 axis robot arm and now I am going to program it to change tools on my mill. I am developing the gripper fingers and tool holding rack today and I am going the direction of having the fingers hold the BT-30 holder while allowing it to rotate and having the spindle rotate slowly to align the holder on insert.
Does that run ROS or something else?
Yes it runs ROS2, i have built out the whole urdf arm model for foxglove but i havnt built the 1100mx mill model or interface yet. Hoping I can get away with the usb interface board and hooks. I trained it to play chess with a 2 camera system and it’s got good accuracy down to .8mm but I’m getting a lot of flex from the plastic so I have been machining the 2 lower joints from aluminum.
Wow, that’s pretty slick. I ran a nachi robot arm with a high speed router mounted on it. Auto assembly size. Machined holes access panels in square fiberglass tubing. Thing could throw you through a wall.
Well the electrics are rated to 8Kw but I’m running it with 1Kw. It’s all 3d printed, but I have made the lower 2 joints from aluminum and I am replacing them today. I programmed the whole thing with Claude and it’s scary writing safety systems for a 35Lb robot with a plastic structure. Aluminum frame on the main joints will take all the flex out of the frame and bring my accuracy down to .8mm. The parts cost about $2,000 so it’s more than a stocking stuffer. -although it could be used to stuff stockings.
Any reason not to use the spindle orient the MX does for ATC changes? Seems like you could bolt a BT30 ATC fork as a gripper and use the back half of the toolchange ATC process more or less as-is if the arm can hold the tool about where the ATC would.
Extra clever would be two of them, one for the incoming tool and one for the outgoing like the swing-arm tool swappers.